We are a second semester senior design team in our capstone class. Using our Electrical Engineering, Computer Science, and Computer Engineering backgrounds, we are navigating the quadcopter, robotics, and vision processing spaces to complete an autonomous drone project.
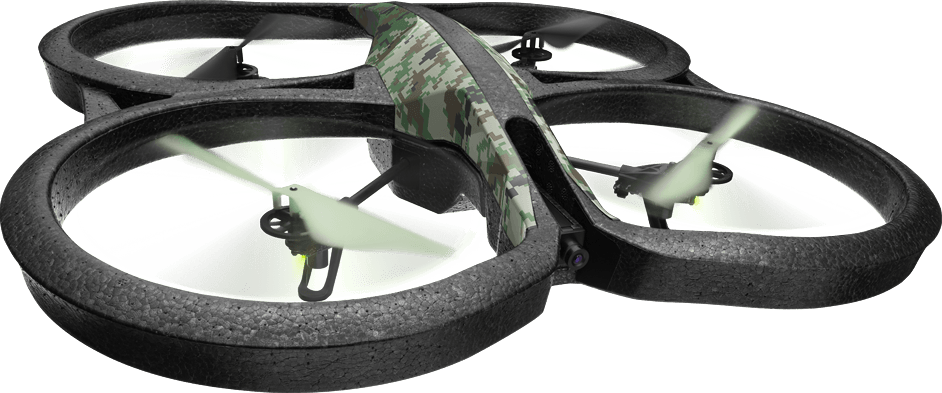
For this project we are using the Parrot AR Drone 2.0. This drone provides a front and bottom camera, internal stabilization, and a reasonable price into one quadcopter. By combining manual control, colored object following, and line recognition, we intend to navigate the Min Kao EECS building on campus. Indoor navigation proves challenging because of an inability to use GPS, and an increase in stability requirements. Check out our progress on Github and YouTube!
Currently our code is implemented on a Raspberry Pi 3 running Ubuntu 16.04.1 LTS (Xenial Xerus). Manual control is run via socket connections in the ARDrone library. Object following uses Kalman Filtering combined with HSV detecting to remain near a human. Line detection is processed through openCV. For more information, check out the cvdrone repository on Github.